Perception processing
Combine information from multiple sources to identify targets and changes in the environment.
 Panoramic AI
MemX-Brain-01
Drive action generation and autonomous work, building lasting memory and understanding of the environment, the task, and the robot itself.
Explore capabilities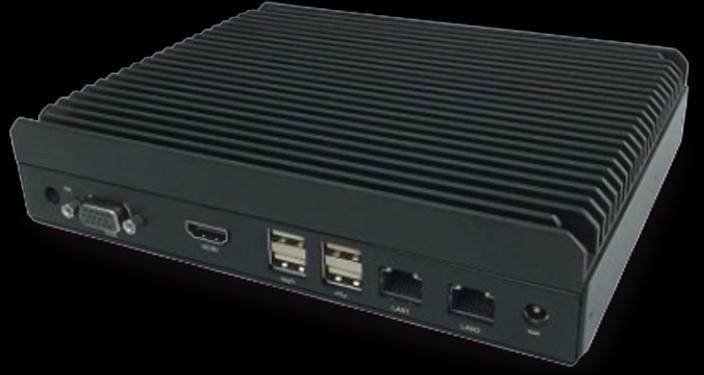
Connect live perception, task state, and execution feedback to keep memory up to date and preserve context.
Combine spatial understanding and embodied models to plan, adapt, and resume when conditions change or work is interrupted.
Connect perception, control, and skill interfaces, adapting to each robot body and application.
MemX-Brain-01 combines hardware and software in a memory-driven embodied intelligence platform for long-term autonomous work. It brings together live perception, task state, past experience, and execution feedback to build task memory that can be continuously updated and recalled on demand, alongside hierarchical reasoning and dynamic decision-making.
Help robots retain task progress, assess changes on site, and adapt their actions in complex real environments, supporting continuous execution of long, multi-step tasks.
Connect memory to understanding, planning, and execution, using each round of feedback to guide what happens next.
Combine information from multiple sources to identify targets and changes in the environment.
Understand locations, spatial relationships, and changes in state.
Interact through natural language to clarify tasks and report results.
Break tasks into steps, with support for inserting, cancelling, and adjusting tasks.
Use current observations and past memories to assess execution conditions and handle exceptions.
Coordinate navigation and manipulation, track execution feedback, and resume tasks.
Support for sensor connections, navigation and manipulation interfaces, robot skill adaptation, system integration, and development.